
-
Our new ticketing site is now live! Using either this or the original site (both powered by TrainSplit) helps support the running of the forum with every ticket purchase! Find out more and ask any questions/give us feedback in this thread!
You are using an out of date browser. It may not display this or other websites correctly.
You should upgrade or use an alternative browser.
You should upgrade or use an alternative browser.
super express acceleration?
- Thread starter TheWalrus
- Start date
- Status
- Not open for further replies.

Sponsor Post - registered members do not see these adverts; click here to register, or click here to log in
R
RailUK Forums
Hi
Does anyone know how to work out the acceleration (m/s^2) with a power(kW)/weight(tonnes)=11.53?
Cheers
Ryan
PS i'm not interested in any comments saying iep won't happen!
There are lots of variables which your equation containing power and weight will fail to address. Most important are the adhesion characteristics and the transmission system for getting power to the rail, then you need to know how much power is taken by air-conditioning and all other electrical systems on the train, and as speed increases so aerodynamic efficiency will come in to play too.
I don't think anybody outside of the IEP project will have any information on these variables and therefore coming up with a true and accurate figure could be very difficult indeed to obtain.
I don't wish to sound negative, just saying it as I see it.
The Planner
Veteran Member
- Joined
- 15 Apr 2008
- Messages
- 19,723
You'll find that even if it has a high acceleration figure it wont be utilised fully. If you give it the beans from a stand then it isnt hugely comfortable for the passengers and then you have the problems with slipping etc. About 0.6m/s^2 as a limit gets quoted a lot.
What you need to have is a high acceleration across a high range of speed. With most units apart from Pendos it drops off fairly rapidly once you are on the move.
What you need to have is a high acceleration across a high range of speed. With most units apart from Pendos it drops off fairly rapidly once you are on the move.
notadriver
Established Member
- Joined
- 1 Oct 2010
- Messages
- 3,737
The 395s can reach 100 from a standing start in 90 seconds. Their power to weight ratio is superior to a Pendolino.
what is the power/weight figure of a 395?The 395s can reach 100 from a standing start in 90 seconds. Their power to weight ratio is superior to a Pendolino.

90019
Established Member
The 395s can reach 100 from a standing start in 90 seconds. Their power to weight ratio is superior to a Pendolino.
That comes out as approx. 0.497 m/s/s, so 0.6 must be fairly rapid.
Edit: about 74s for 0.6.
WatcherZero
Established Member
- Joined
- 25 Feb 2010
- Messages
- 10,272
Though Metro/Light rail have lower top speeds (43.5mph, 50mph a few 60mph) their acceleration is considerably better, often topping out at 1.3 m/s half load which is considered the fastest comfortable acceleration.
cyclebytrain
Member
- Joined
- 11 Jul 2009
- Messages
- 311
Depending upon what you want it for, an exceedingly crude model would be going down the energy route (k.ei = 1/2 * mi * vi^2)
If I can trust the quick rearrangement I've just done (it is a bit early in the morning right now, so it may not be right) the equation you want would be:
a = sqrt((2 * P / m) - v1 ^2) - v1
where power is in W and m in Kg and v1 is the initial speed in m/s
Assuming you want a standing start, v1 = 0 and the equation simplifies another step to:
a = sqrt(2 * P / m)
Again, this is a very crude model, done whilst I'm bleary eyed; so you shouldn't rely upon it, but it can probably give you a rough feel.
Hopefully this has given you some helpful pointers anyway!
The Planner
Veteran Member
- Joined
- 15 Apr 2008
- Messages
- 19,723
Though Metro/Light rail have lower top speeds (43.5mph, 50mph a few 60mph) their acceleration is considerably better, often topping out at 1.3 m/s half load which is considered the fastest comfortable acceleration.
Surprising, I know most consultants and NR wont use more than 0.6 when computer modelling passenger trains.
WatcherZero
Established Member
- Joined
- 25 Feb 2010
- Messages
- 10,272
Indeed, its more bus like foot to the pedal if your not anticipating it you go flying however 
Buses accelerate considerably harder, just checked spec sheet for Optare Solo claiming it can do 0-100kmh in 11.9 seconds! thats 2.33 m/s
Buses accelerate considerably harder, just checked spec sheet for Optare Solo claiming it can do 0-100kmh in 11.9 seconds! thats 2.33 m/s
Last edited:
swt_passenger
Veteran Member
- Joined
- 7 Apr 2010
- Messages
- 34,307
Hitachi's data sheet for the IEP gives the acceleration of all variants as 0.75 m/s/s...
Oh...Well that's really what I needed! Thank you!Hitachi's data sheet for the IEP gives the acceleration of all variants as 0.75 m/s/s...

So if I wanted to know what speed it gets to in a minute, I would do 0.75x60x60? Or am i totally wrong??

Lampshade
Established Member
Hitachi's data sheet for the IEP gives the acceleration of all variants as 0.75 m/s/s...
That's pretty quick
 hock:
Wonder what the acceleration is of a 323, they can really shift.
Last edited by a moderator:

asylumxl
Established Member
So if I wanted to know what speed it gets to in a minute, I would do 0.75x60x60? Or am i totally wrong??
6039.72799 mph? Seems off.

To the best of my knowledge it is..
original speed + (acceleration x time) = final speed
Roughly 100mph.
The Planner
Veteran Member
- Joined
- 15 Apr 2008
- Messages
- 19,723
Hitachi's data sheet for the IEP gives the acceleration of all variants as 0.75 m/s/s...
For what range though, I bet that drops off considerably as soon as it gets to about 20-25mph.
0.75x6Ox6O=162000mpm=162km/m...no that's so wrong.6039.72799 mph? Seems off.
I'm laughing at the equation failures here calculating the 0.75m/s2, it's quite silly. If we assumed linear acceleration of 0.75ms2 and ignore drop off, that works out at 0.75*60=45m/s to convert that (45*3600)/1609.344=100.66mph after 60 seconds accelerating at a constant 0.75m/s2
Surely thats not possible!I'm laughing at the equation failures here calculating the 0.75m/s2, it's quite silly. If we assumed linear acceleration of 0.75ms2 and ignore drop off, that works out at 0.75*60=45m/s to convert that (45*3600)/1609.344=100.66mph after 60 seconds accelerating at a constant 0.75m/s2
Surely thats not possible!
mumrar's working looks fine to me. Remember that essentially his calculation is in a perfect scenario assuming no wind resistance, rail resistance or slippage and no power drop off. In the real world it would be giving a different result.
Yep, I don't think it achievable, in reality the acceleration will drop off from about 25-30mph, but I was just showing how the calculation should have been done for that figure and 60 seconds, rather than some of the silly ones posted above
asylumxl
Established Member
I'm laughing at the equation failures here calculating the 0.75m/s2, it's quite silly. If we assumed linear acceleration of 0.75ms2 and ignore drop off, that works out at 0.75*60=45m/s to convert that (45*3600)/1609.344=100.66mph after 60 seconds accelerating at a constant 0.75m/s2
Which is the equation I put up...
Assuming the acceleration is linear, it'd take roughly 74.5 seconds to 125mph and 83.5 to 140mph.
Last edited:
Peter Sarf
Established Member
Which is the equation I put up...
Assuming the acceleration is linear, it'd take roughly 74.5 seconds to 125mph and 83.5 to 140mph.
From what I remember the snag is ACCELERATION IS NOT LINEAR. Acceleration falls off with speed if the power remains constant. Assuming the train/object is working at maximum power then we are stuck with that constant power. I know that the transmission can be designed to use the power at low speed to give acceleration ( like a low gear in a car ) OR to give a high speed ( like a high gear in a car ).
In the case of rail the maximum power is not always usable at low speed because of the limit of adhesion (wheelslip). There is also the possibility of overloading the transmission at low speed - I seem to remember that class 47 (Brush Type 4) locos could easily burn out their traction motors if the driver was over enthusiastic up to about 20mph (I think).
You generally have a choice between achieving a high maximum speed or lower speed but with better acceleration. An intercity train benefits from as few stops as possible because it cannot accelerate back up to maximum speed easily. A suburban/commuter train will have a lower maximum speed but better acceleration because most time is saved getting away quickly from frequent stops and a top speed is hardly ever reached in such short stretches.
BUT if you install MORE power you can always get something that can accelerate like a suburban/commuter train but still fly along with the intercity trains. I am refering to the 350s which allegedly can accelerate hard but also be able to get upto the same speed as the 390s (Pendolinos) because they share the same pair of tracks on the West Coast Mainline. The snag is your using more power which costs money and polution (from the powerstation).

sprinterguy
Veteran Member
Accelerating from a stand, the traction motors can exert a maximum power output, that can only be sustained for a short period of time, above the continuous rating for the motors. That's why class 47s could burn out their traction motors with a concerted effort at starting a train from a stand, as the maximum power output is exceeded. As Peter Sarf says above, acceleration soon drops off as speed increases, as does the maximum power output of the traction motors as the exerted power falls into line with the continuous power rating that can be sustained for an extended period of time.
It’s the ratio of the gearing that governs the maximum rail power that can be exerted in starting a train: A low gearing gives for good acceleration but a lower top speed, as the maximum rail power is a greater percentage above the continuous motor rating, making it easier to lift a train off the mark. A high gearing gives a slower acceleration, but a high top speed. A class 08 shunter for example is able to haul a forty wagon HAA rake, despite it having only 350hp at its’ disposal, as it is very low geared, with a starting tractive effort THREE TIMES that of the continuous rating it can sustain. But of course the locos are limited to just 15mph. A class 91 electric locomotive, with a 140mph top speed, has a high gearing that means it accelerates slower off the mark (with a comparative train), as the maximum power output is not much higher than the 6090hp continuous rating.
Distributed power seems to give better acceleration than a single locomotive with the same power output, as distributed power spread over a number of traction motors on more axles gives a bigger tractive effort at the railhead.
Bascially if you plot power output against acceleration over time you end up with curved graphs, not straight lines.
Last edited:
I am refering to the 350s which allegedly can accelerate hard but also be able to get upto the same speed as the 390s (Pendolinos) because they share the same pair of tracks on the West Coast Mainline. The snag is your using more power which costs money and polution (from the powerstation).
They can't - 350s go to 100, 390s to 125 (140 technically). A 350 will easily outstrip a 390 to around 60, then gets its socks knocked off up to 100. 350s are one of the fastest accelerating units currently in use.

TGV
Member
There is some pretty suspect physics going on here! There is no point in quoting a single figure of acceleration without any backup data.
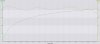
Here's some reality for you. Attached is a speed/distance graph of an HST - a real one, not a theoretical one. You can clearly see how the acceleration curve (the green line) is very non-linear. If you plotted this against time instead of distance, the curve would be very similar in shape, albeit stretched or squashed depending on the scale on the x-axis.
That figure I read somewhere of 0.75m/s2 will only apply at one moment in the curve - presumably the maximum figure (or steepest gradient in the acceleration curve which gives that figure), so that's what they're quoting.
ANY train (or vehicle for that matter) accelerates by and large, with the same kind of curve, but the acceleration curve shape will simply be changed by the traction the train has (down low) and the power it has (up top). Tube trains leave everything for dead from a standing start (especially those new Victoria Line ones), but if any of you have been on a TGV accelerating between 160 and 180mph - it's astonishing. Gearing, too has an effect as much as power, mass and adhesive weight have.
Here's a similar issue discussed on an automotive forum after Autocar magazine ran some 0-100-0mph tests on road cars, then compared them to an F1 car: The F1 car managed 0-62mph (100km/h) in 2.2s, but most of that happened in the last 1.2 seconds after power/traction issues were resolved and aero effects allowed more power to be applied). They tested a Subaru Impreza 22B, which managed to get to 32mph QUICKER than the F1 car despite having 1/3 the power and over double the weight (it has 4 wheel drive and without any aero effect at a standstill, has greater traction). So you could say it's acceleration was greater than the F1 car if you're only looking at a portion of the curve between 0 and 30mph, but of course, the real picture is different. The Scooby had only just got to 60mph in the same time the F1 car went from stationary to 100mph and back to stationary again.
EDIT: Incidentally - you can see that the HST took nearly 15 miles to get to 125mph - although that's not necessarily with full power all the way, but it IS indicative of typical service performance.
Attachments
asylumxl
Established Member
Hence I said "assuming linear acceleration". Unless you've got the acceleration curve for the IEP, a train that doesn't and probably won't ever exist, there's not much else to go on is there?
TGV
Member
Hence I said "assuming linear acceleration". Unless you've got the acceleration curve for the IEP, a train that doesn't and probably won't ever exist, there's not much else to go on is there?
I'm not intending on getting at anyone in particular. While there may not be any direct evidence to go on, we can extrapolate from known data if we had the time and could be bothered.
All I'd say is that an assumption like that is so far from reality that in my business, it's best not to assume at all. No offence intended to anyone.
The Planner
Veteran Member
- Joined
- 15 Apr 2008
- Messages
- 19,723
EDIT: Incidentally - you can see that the HST took nearly 15 miles to get to 125mph - although that's not necessarily with full power all the way, but it IS indicative of typical service performance.
Bet thats a FGW HST ??, XC and East Coast drivers are a lot less cautious from a stand.
- Status
- Not open for further replies.