
Found this article from the industry puff piece maker International Railway Journal. It's the only article I've found that actually goes into detail on how Rio Tinto's driverless trains work:
 www.railjournal.com
Rise of the machines: Rio Tinto breaks new ground with AutoHaul
History was made on June 14 2019 when Rio Tinto completed the transition to entirely automated operation of its 1500km railway in the Pilbara region.
www.railjournal.com
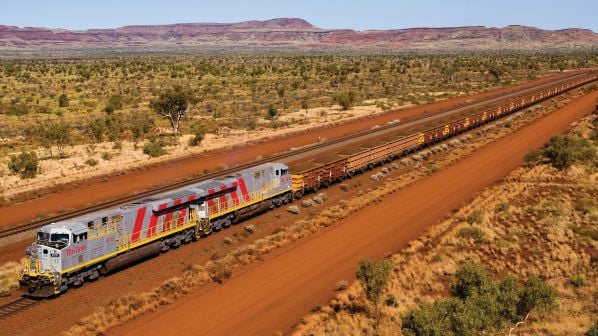
Obviously this raises the question of whether or not such automation could be imitated elsewhere - private freight operators in plenty of places would be extremely happy to eliminate crews. Does anyone with more experience in this topic have any insight as to how applicable Rio Tinto's system could be to other networks?Described by Rio Tinto as the world’s largest robot, AutoHaul is operating up to 50 automated and unmanned trains at any one time. Each 240-wagon, 2.4km-long consist, requires two to three locomotives, which haul 28,000 tonnes of iron-ore from the company’s 16 mines to the ports of Dampier and Cape Lambert on an average 800km, 40-hour journey.
Manned operation remains for last mile at the ports, with drivers joining the trains at the end of the main line. Loading and unloading of product from the wagons is also a completely automated process.
[...]
The AutoHaul system is equivalent to ERTMS Level 2 and has been installed by Hitachi Rail STS under a contract awarded in 2012 as part of the Rio Tinto Iron Ore-Ansaldo STS Framework Agreement established in 2010.
Hitachi Rail STS developed and delivered an automated train management system including a centralised vital safety server (VSS), which is essentially a radio block centre (RBC), the wayside element of the application, and supports the safe and flexible management of train movements. The supplier also delivered upgrades to locomotive control systems to support the deployment of electronically-controlled pneumatic (ECP) braking, overseeing installation and system integration of ECP braking on Rio Tinto’s 200-strong locomotive fleet. In addition, the locomotives are fitted with collision detection systems; automatic train protection (ATP) technology, which controls train speed and adheres to speed limits; and an onboard video camera to record the forward view of the train.
Fenzi says there are a couple of fundamental differences between a conventional ERTMS Level 2 application and the AutoHaul project. Firstly, the system does not use GSM-R for train-to-ground communication. Fenzi says that because the application is taking place outside Europe, the supplier was not obliged to follow this protocol. Rio Tinto also requested that the system use the railway’s existing data/UHF radio network, which is supported by 60 base stations located across the network, and was upgraded to meet the demands of the new system. Extensive testing in instances of high traffic was conducted to ensure reliability with multiple layers available in case the system falls out. These consist of a back-up fibre optic network and a satellite-based system, which is able to provide seamless and continuous communication to the trains.
The ATP system itself uses an interlocking which sets the route according to the commands received by the train control system. The VSS receives the route from the interlocking and transmits this to the onboard unit, providing the movement authority, which follows the distance-left-to-run principle. Like an ETCS application, the system uses a network of balises for group referencing and to run the trackside elements. However, there are what Fenzi describes as several peculiarities. Most notably is the presence of integrated asset protection across the entire system, which can automatically trigger a change to the limit of authority for the train according to an alarm generated on the wayside due, for example, to an issue at one of the network’s 42 level crossings. This process occurs through the same chain: through the VSS and via the radio to the onboard unit.
The ATO element relies on two separate channels - one from the control centre and the other from the onboard unit, which are linked together and communicate with one another.
First, the ATO system gathers the information from the ATP system on the current journey, the speed and location of the train, from which the system performs its own calculation for operation. These calculations are also informed by information from the other channel from the control centre.
Unlike the ATP data, this information is not safety-related but necessary for the journey itself. This includes the schedule as defined by the operator and the information required for the driving strategy, a sub element of the ATO, which includes the track map, a database of the entire network and the algorithm which enters and monitors the train’s journey while it is in service. Connected to this is data for external elements essential for operation such as the throttle, brakes, horns, locomotive information and data loggers.
“All the actions that the driver would make now have to be performed by the system and/or the rolling stock asset evaluator which sits in the control centre and basically monitors all of the trains and locomotives,” Fenzi says. “They make decisions that a driver would do if sitting in a cab. There are some critical actions taken by the system whereas others are monitored remotely by the controller who can decide to act immediately or later on.”
[...]
Special attention was paid to the network’s level crossings as the greatest area of risk with the public when developing the AutoHaul system. These are fitted with lighting, CCTV and a laser-based obstacle detection system which is connected to the ATP. The 4K HD cameras provide a clear view of the crossing, far superior to the driver’s line-of-sight perspective.
[...]
The first stage was the rollout of the ATP system as a vital safety system covering the entire network, providing the framework for the subsequent deployment of ATO. In the second phase, the driver remained in charge of driving, accelerating, braking and coasting the train. However, the ATO system was connected to the Driver Machine Interface (DMI), with the algorithm suggesting the optimal driving profile according to the predetermined driving strategy. In the third and fourth stages, the ATO was connected to the throttle and the brake, and all of the locomotives interfaces, so for the first time the system was able to autonomously drive the train. In the third mode, the driver remained in the cab in a supervisory capacity. In the fourth stage, drivers were removed.
“Attended mode became an important part of the acceptance process and although it lasted a little longer than expected, it was essential to boost confidence in the system among all parties involved,” Fenzi says. “We effectively had someone sitting there ready to intervene but they never did because the system did what it was supposed to do, to the point where everyone had the confidence to remove the person from the cab.”
Robertson says many iterations of the driving strategy were tested in order to retune the system to maximise operating efficiency. AutoHaul received regulatory approval in May 2018 following the successful completion of “many thousands of kilometres” of tests. The very first unmanned loaded train was operated on July 10 2018, running 280km from Tom Price mine to Cape Lambert. Driverless operation was gradually increased over the next few months, reaching 34 trains per day and 45% of daily kilometres operated by October. This had risen to more than 90% of trains operated by February.
[...]
While drivers are now absent from the trains, some are located at strategic locations across the network in case of a problem with the unmanned trains. Manual driving also still takes place in the event of recoveries. However, removing the drivers has helped to deliver some of the project’s most notable enhancements in performance, notably improvements in locomotive fuel efficiency and reduced wear-and-tear on the track and the locomotives. The need for 1.5 million-km of annual road movements to transport drivers to and from trains mid-journey has also been cut.
[...]
Robertson says Rio Tinto is in an advantageous position compared with other railways looking at AutoHaul and the potential difficulty of rolling out similar projects on more complex networks. “The big reason we could do it is that we have a closed private network,” Robertson says. “There is no other railway traffic. It is our trains, train control system, traction system, track infrastructure, mines and ports. Also, the Pilbara is an arid desert, with minimal interaction with people and the rail network.”

